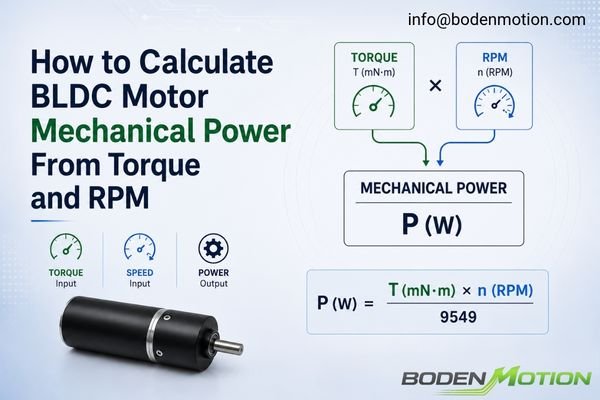
How to Calculate BLDC Motor Mechanical Power From Torque and RPM?
Your new project requires a motor with “10 mN·m torque and 15,000 RPM.” This seems clear, but these two numbers hide a critical third value:
Your new project requires a motor with “10 mN·m torque and 15,000 RPM.” This seems clear, but these two numbers hide a critical third value:
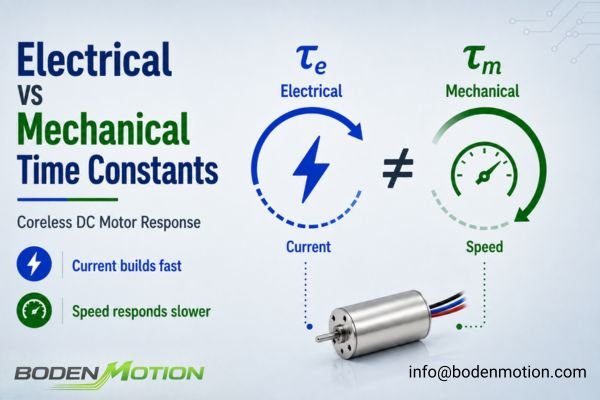
Engineers often select coreless DC motors for their “fast response,” but this term can be misleading. Current might rise quickly while the mechanical system still
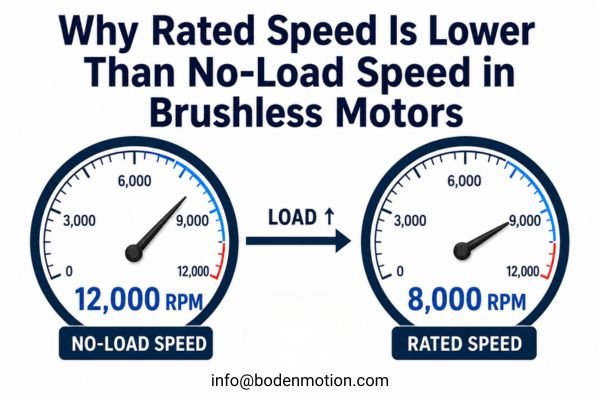
OEM buyers often see a high no-load RPM on a motor datasheet and expect similar performance in their equipment. This can lead to a frustrating
Selecting a motor based on torque alone often leads to disappointing performance in precision robotics. The actuator might be strong, but it feels slow, overshoots
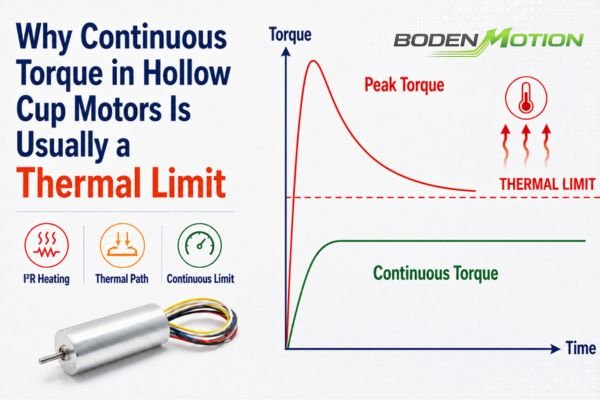
An OEM engineer selects a compact hollow cup motor with an impressive peak torque rating, but it fails to perform under continuous load. The motor
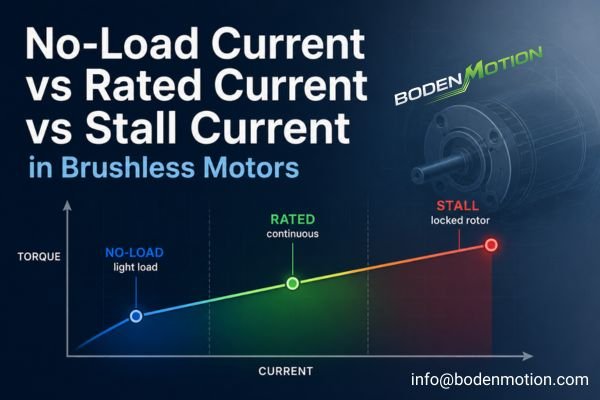
Misinterpreting a motor’s current ratings is a common engineering oversight that often leads to undersized drivers, unexpected thermal issues, or oversized, costly power systems. No-load,
A motor sample that spins is not ready for approval. Functional operation confirms basic function, but it does not establish whether future production units can
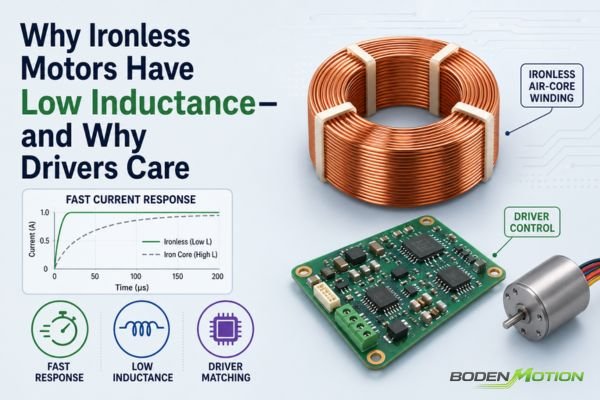
You chose an ironless DC motor for its fast response, but now your driver is overheating or the motor is noisy. The problem often isn’t
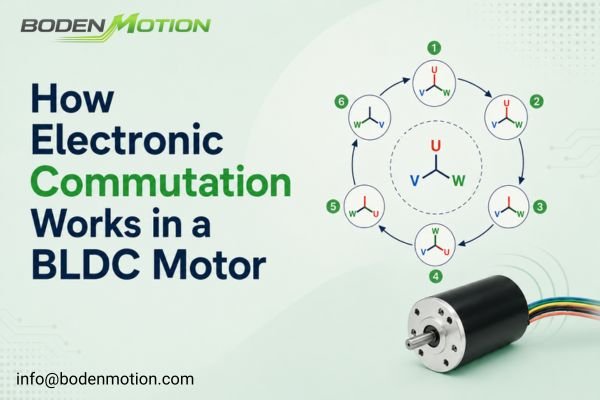
Your brushless motor isn’t starting reliably under load, and you suspect a fault. But “brushless” doesn’t mean “commutation-free”—it just means the switching is electronic, and
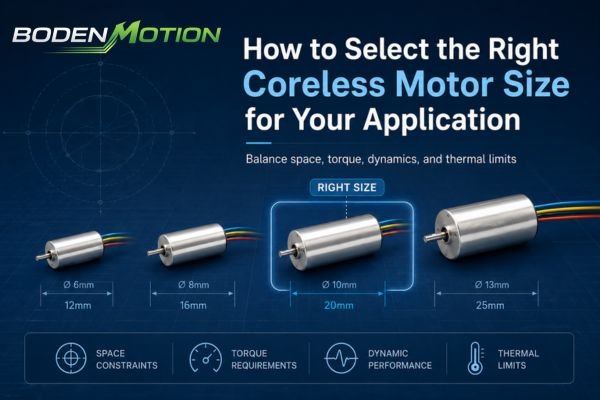
Selecting a coreless motor based on space constraints alone is a common path to system failure. The real goal isn’t finding the smallest motor; it’s
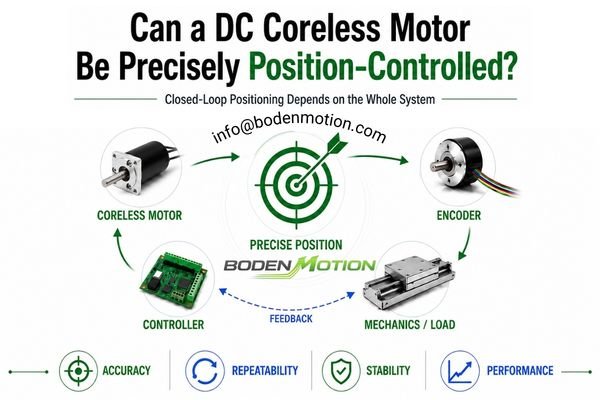
Many projects miss positioning targets because the DC motor is treated as the complete solution. The loop closes through feedback, mechanics, and control, not the
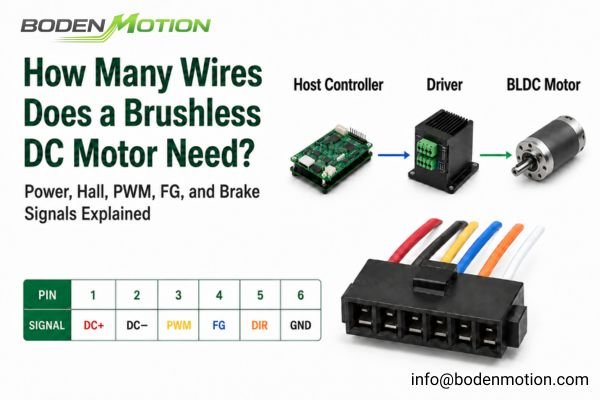
A brushless DC motor may use as few as three phase wires for basic operation, while a sensored version typically adds five Hall sensor wires.