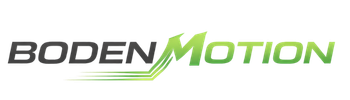
"Can you connect a BLDC motor directly to a battery?" It's a simple question I hear a lot, especially from teams working on portable, battery-powered equipment.
The answer depends first on whether the BLDC motor includes its own commutation electronics. A bare BLDC motor cannot run directly from a battery, while a motor with an integrated driver potentially can, but only if the entire electrical system is compatible.
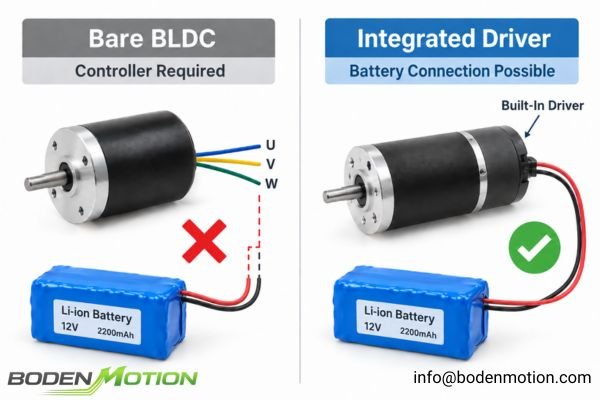
This distinction is the most important one. A brushed DC motor can often rotate when DC voltage is applied directly because its brushes and commutator mechanically switch the current inside the motor.1 A bare brushless DC (BLDC) motor has no such mechanical commutator. It relies on an electronic controller to manage the phase switching required for rotation.2 However, many modern BLDC motor products integrate this controller, presenting a simpler DC interface. The real engineering question isn't just about the motor; it's about whether the complete motor-driver system can tolerate the battery's real-world voltage and current behavior.
Why a Bare BLDC Motor Cannot Normally Run Directly From a Battery
Let's start with the basic electrical architecture. Applying battery power directly to a bare BLDC motor does not provide the commutation required for continuous rotation and can lead to excessive winding current.
A bare BLDC motor requires a controlled sequence of changing currents across its phases to create a rotating magnetic field; a battery only provides a constant DC voltage.
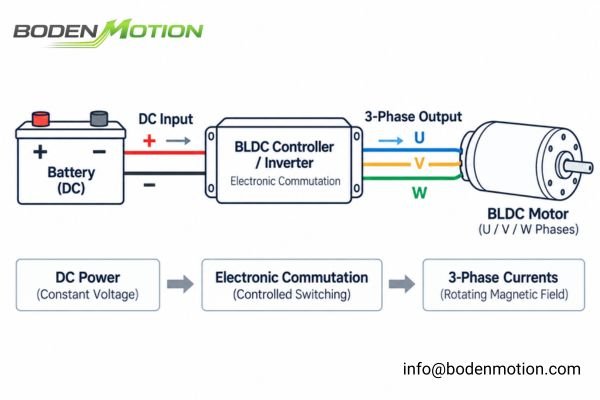
A typical bare three-phase BLDC motor has three phase leads (U, V, and W) and sometimes additional wires for Hall sensors or temperature feedback. These windings must be energized in a specific sequence to pull the rotor's permanent magnets along, creating smooth rotation. This critical function is performed by a BLDC controller or Electronic Speed Controller (ESC).
The proper power path looks like this:
Battery DC → BLDC Controller / Inverter → U / V / W Phase Switching → Rotating Magnetic Field → Motor Rotation
If you connect a DC battery voltage directly across any two of the motor's U/V/W phases, the system will not produce normal rotation.3
- There is no rotating magnetic field.
- The rotor may jerk to one magnetic position and stop.
- Without the commutation sequence and the back-EMF generated during normal rotation, the current can rise rapidly. This current is ultimately limited by the total impedance of the circuit (winding, battery, wires) and can lead to rapid winding heating and potential damage.
- The motor will not achieve continuous rotation.
Key Engineering Insight: The battery supplies DC power, but the motor phases still require electronically controlled commutation to produce continuous rotation. The BLDC controller's job is to create this commutation sequence.
When Can a BLDC Motor Be Connected Directly to a Battery?
The situation changes completely when the motor assembly already includes the necessary electronics.
A BLDC motor with an integrated driver board can often be connected to a battery's DC supply because the required commutation and control logic is already built into the motor package.
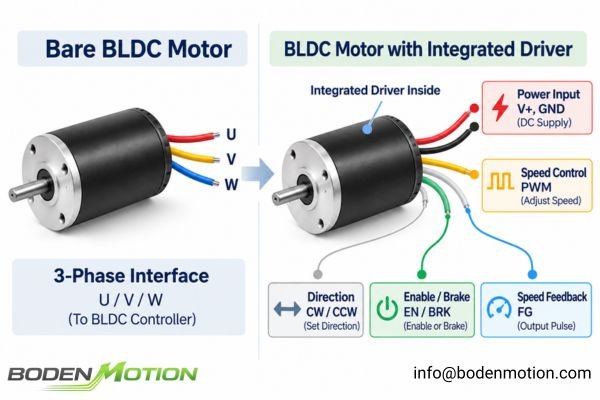
These "smart" motors are designed for easier integration. Instead of external U/V/W phase leads, their interface often looks more like a brushed DC motor's, with connections for:
- Power (V+, GND)
- Speed Control (e.g., PWM or Analog)
- Direction (CW/CCW)
- Enable/Brake
- Feedback (e.g., FG speed pulse)
Even with these motors, "direct connection" is possible only if several critical conditions are met. The connection is to the battery's DC bus, not directly to the motor windings.
| Motor Type | Battery Direct Connection | What Is Still Required |
|---|---|---|
| Bare 3-phase BLDC | No | External BLDC controller |
| Hall BLDC motor without driver | No | Driver using Hall feedback |
| Sensorless BLDC without driver | No | Sensorless controller/ESC |
| BLDC with integrated driver | Potentially yes | Correct DC supply and control interface |
| BLDC module with full controller | Usually possible within specs | Battery/BMS compatibility check |
Why Battery Voltage Must Be Checked as a Range, Not a Single Number
A common OEM integration mistake is matching a "12V" motor to a "12V" battery and assuming compatibility. This overlooks the battery's actual operating voltage range.
A battery's voltage is not a fixed number; it's a dynamic range that depends on charge level, load, and temperature. This entire range must fit within the motor driver's allowable input voltage window.
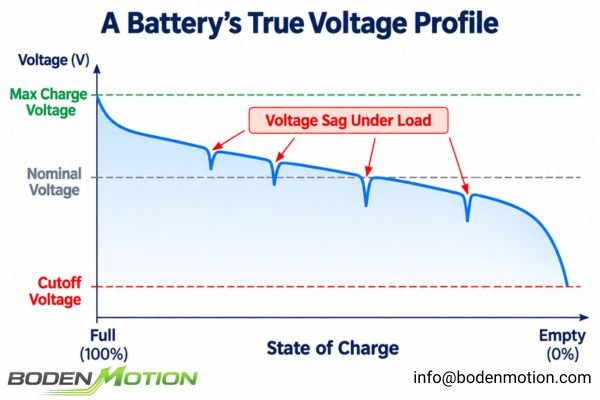
A battery's nominal voltage is a reference value, not a fixed operating voltage. The actual voltage varies significantly:
- Fully Charged Voltage: A fully charged battery's voltage is higher than its nominal rating. For example, a 3S (3-cell series) Li-ion battery with an 11.1 V nominal rating can be 12.6 V fresh off the charger.4
- Discharged Voltage: As the battery discharges, its voltage drops. Depending on the cell specifications, load conditions, and BMS cutoff strategy, some 3S systems may approach approximately 9.0 V near their discharge cutoff.5
- Voltage Sag: When a heavy load draws a large current, the battery's output voltage will temporarily dip due to its internal resistance6.
A practical example is the BDCL1525 coreless BLDC motor platform, which is available with 9 V, 12 V, 18 V, and 24 V winding configurations. While they share the same mechanical platform, their electrical characteristics—including resistance, current demand, and speed constant—differ significantly. This illustrates why a motor's nominal voltage should not be treated as a simple label. Importantly, the winding voltage does not mean the bare three-phase motor can be connected directly to that battery voltage. A compatible BLDC controller is still required for electronic commutation.7
| Battery Characteristics | Motor/Driver Specifications |
|---|---|
| Max charged voltage | Maximum recommended operating input voltage (and below the absolute maximum limit) |
| Nominal operating voltage | Nominal operating voltage range |
| Minimum cutoff voltage | Undervoltage lockout (UVLO) threshold |
Real Integration Challenge: A driver with a 12 V absolute maximum input voltage is not compatible with a 3S Li-ion battery that reaches 12.6 V when fully charged. The battery voltage would exceed the driver's absolute maximum rating, creating a risk of permanent damage to the driver electronics. In normal operation, the battery's full voltage range should remain within the driver's recommended operating input range as well as below its absolute maximum limit.
Why Startup Current and the BMS Can Cause Repeated Restarting
You've checked the voltage ranges and they match. You connect the system, and the motor just twitches, clicks, or tries to start and immediately stops, over and over. This is a classic integration problem.
A battery may have enough stored energy (capacity) but still be unable to deliver the peak current required during motor startup, often due to limits in the Battery Management System (BMS).
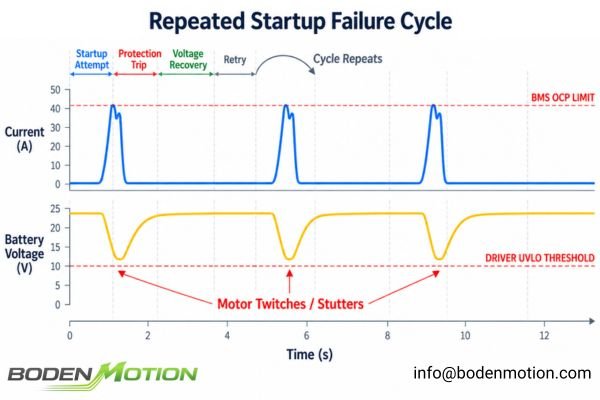
A typical failure pattern in battery-powered systems looks like this:
- The driver attempts to start, demanding a high startup current to accelerate the rotor and mechanical load.
- This high current draw causes the battery's voltage to sag, or it exceeds the BMS's over-current protection (OCP) threshold.8
- The BMS cuts power to protect the battery, or the driver's undervoltage lockout (UVLO) trips due to the voltage sag.
- The driver shuts down. The load is removed.
- The battery voltage recovers, and the BMS may reset.
- The driver, seeing valid voltage again, attempts to restart the motor.
- The cycle repeats, resulting in a twitching or "stuttering" motor that never successfully spins up.
Resolving this requires looking at the entire power delivery system:
- Motor/Driver: What is its peak startup current demand?
- BMS: What are its continuous and peak current limits, and what is the trip delay?
- Battery: What is its C-rating (discharge capability) and internal resistance?
- Wiring: Are the wires and connectors thick enough to handle the peak current without significant voltage drop?
Speed Control, Protection, and Regeneration Still Matter
Even if the motor starts successfully, integration isn't finished. Connecting power is just the first step.
A successful battery-powered BLDC system requires proper implementation of speed control, fault protection, and careful consideration of any regenerative energy.
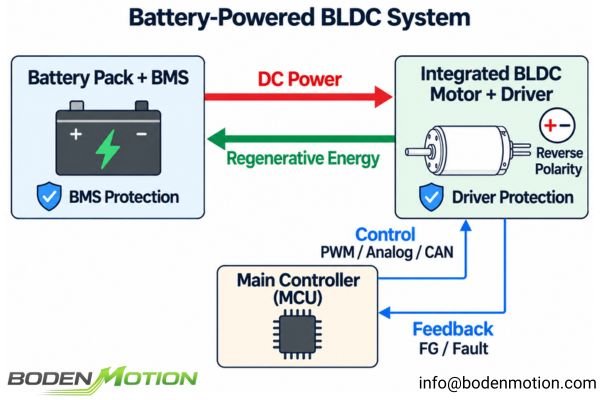
Key system-level considerations include:
- Speed Control: How does the integrated driver expect to be told how fast to run? It could be a PWM signal, an analog voltage, or a digital command via a bus like CAN or RS-485. Simply applying power might only make it run at a default or maximum speed.
- Protection: What happens if the motor stalls? Depending on the driver, protection may include over-current, short-circuit, thermal shutdown, and undervoltage lockout (UVLO). The protection thresholds and restart behavior should be understood before integration. Driver UVLO helps prevent unstable operation at insufficient bus voltage9, while the battery/BMS cutoff protects the cells from excessive discharge.
- Reverse Polarity: Reverse-polarity connection can damage driver electronics if adequate protection is not built into the system. Check whether the driver includes reverse-polarity protection or whether it must be added externally.
- Regenerative Energy: If the driver topology and braking strategy allow regenerative energy to return to the DC bus, rapid deceleration or back-driving can raise the bus voltage. If the battery's BMS is not designed to accept this charging current, it could trigger an overvoltage fault or damage the system.
What OEM Buyers Should Provide Before Connecting a BLDC Motor to a Battery
To ensure a successful integration, the conversation with your motor supplier needs to be much more detailed than "I need a 12V motor for my battery."
Provide a complete electrical and mechanical operating profile so your motor partner can evaluate the compatibility of the motor, driver, battery, BMS, and load as a complete system.
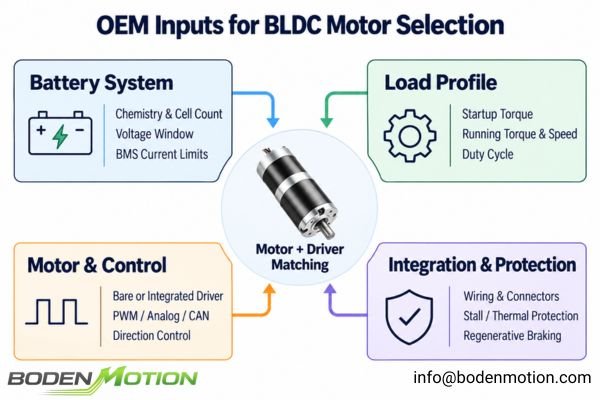
To move from guesswork to engineering, a useful inquiry provides the following:
- Motor/Driver: Is a bare motor or an integrated-driver solution preferred?
- Battery: What is the chemistry (e.g., Li-ion, LiFePO4), cell count (e.g., 3S, 4S), and capacity (Ah)?
- Voltage Window: What are the maximum fully charged voltage and minimum cutoff voltage of the battery pack10?
- BMS Limits: What are the continuous and peak current limits and the trip duration?
- Load Profile: What is the startup torque11? What is the continuous running torque and speed?
- Control Interface: How will you control speed and direction (e.g., PWM, Analog, CAN bus)?
- Wiring: What are the planned wire gauge and length? What connectors will be used?
- Protection: Are there specific requirements for stall detection, thermal shutdown, or regenerative braking?
For battery-powered OEM applications, BODENMOTION can evaluate the motor winding, driver requirements, battery voltage window, startup load, target speed, and control interface together before sample selection.
BLDC Motor-to-Battery Compatibility Decision Tree
So, can you connect your BLDC motor to a battery? Follow this engineering decision-making process.
Successful integration depends on a series of system-level checks: motor architecture, voltage range, startup current, BMS limits, control interface, and protection must all be compatible.
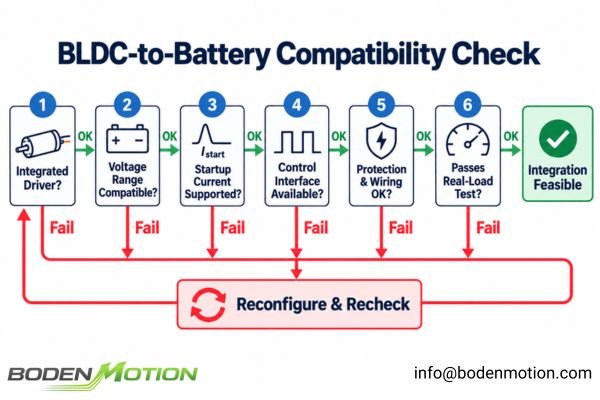
Step 1: Does the Motor Have an Integrated Driver?
- No: You cannot connect it directly. You must add an external BLDC controller between the battery and the motor.
- Yes: The motor has built-in commutation electronics. Proceed to Step 2.
Step 2: Is the Complete Battery Voltage Range Inside the Driver Input Range?
- No: The system is incompatible. You must change the battery configuration, select a different driver, or add a suitable DC-DC converter.
- Yes: The voltage is safe. Proceed to Step 3.
Step 3: Can the Battery and BMS Supply the Required Startup Current?
- No: Startup will likely fail or cause repeated resets. You may need a battery with a higher discharge rating, a BMS with higher current limits, or a driver with soft-start capabilities.
- Yes: The system can provide the necessary startup power. Proceed to Step 4.
Step 4: Is the Required Control Interface Available?
- No: The motor cannot be controlled as required. You may need a different motor/driver or an intermediary controller to generate the correct signals (e.g., PWM, analog voltage).
- Yes: You can command the motor as needed. Proceed to Step 5.
Step 5: Are Protection and Wiring Requirements Satisfied?
- No: The system is unsafe or unreliable. Redesign the electrical path with appropriate fuses, reverse-polarity protection, and correctly rated wires and connectors.
- Yes: The physical connections are robust. Proceed to the final test.
Step 6: Validate Under Real Load Conditions
The final step is to test the complete system under representative and worst-case operating conditions, including cold start, maximum load, low battery, and high ambient temperature.
| Question | If No | If Yes |
|---|---|---|
| Integrated commutation electronics? | Add BLDC controller | Check voltage |
| Battery voltage within input range? | Change system configuration | Check current |
| BMS supports startup current? | Increase current capability / reduce startup demand | Check controls |
| Required control interface available? | Add compatible controller/interface | Check protection |
| Wiring and protection adequate? | Redesign electrical path | Test under real load |
| Passes full-load battery test? | Re-evaluate motor/system matching | Integration is feasible |
Conclusion
A bare BLDC motor cannot be connected directly to a battery; it requires an external controller for commutation. A BLDC motor with an integrated driver can be connected to a battery's DC bus, but this is not a guarantee of system compatibility. Engineers must validate the entire power path: motor architecture, battery voltage range, startup current capability, BMS limits, control interface, wiring, and protection.
For battery-powered OEM equipment, final motor and driver selection should be validated under the actual battery voltage range, startup load, operating speed, and worst-case load conditions. Technical inquiries can be sent to info@bodenmotion.com.
FAQ
Q1: Can I connect a three-phase BLDC motor directly to a battery?
Not if it is a bare three-phase BLDC motor. It requires an electronic controller to perform phase commutation. Applying battery voltage directly across the motor phases will not produce continuous rotation and may cause excessive winding current.
Q2: Why can some BLDC motors connect directly to DC power?
These motors contain an integrated driver and controller that converts the DC supply from the battery into the required electronically commutated phase currents needed for the motor to run.
Q3: Can a 12V BLDC motor run from any 12V battery?
Not necessarily. You must check that the battery's full-charge voltage does not exceed the motor driver's maximum input voltage, and that its low-charge voltage is above the driver's undervoltage lockout threshold.
Q4: Why does my BLDC motor start and then repeatedly reset?
A common cause is that the motor's startup current demand triggers the battery's BMS over-current protection or causes the voltage to sag below the driver's undervoltage shutdown threshold.
Q5: What information should OEM buyers provide for battery-powered BLDC selection?
Provide the motor/driver architecture, battery chemistry and cell count, full voltage range, BMS continuous and peak current limits, startup load, target RPM, and control interface requirements.
GlobalSpec, "Brushed DC Motor Working Principle." The article explains how brushes and a commutator switch current through the motor windings as the rotor turns, allowing a brushed DC motor to produce continuous rotation from a DC supply. ↩
Wikipedia, "Brushless DC electric motor." The article explains that a BLDC motor replaces the mechanical brush-commutator system with an electronic controller that switches current through the motor windings to maintain rotation. ↩
Renesas, "What are Brushless DC Motors?" The guide explains that BLDC rotation requires the magnetic field produced by the stator windings to change continuously, which in turn requires controlled switching of current through the motor coils rather than a simple positive-and-negative battery connection. ↩
Wikipedia, "Lithium-ion battery." Common 3.7 V nominal lithium-ion cells can reach about 4.2 V at the top of charge, so three such cells connected in series correspond to approximately 11.1 V nominal and 12.6 V fully charged. ↩
Large Battery, "Lithium Battery Discharge Cutoff Voltage." The article notes that lithium-ion discharge cutoff voltage depends on cell and protection settings and that some systems use about 3.0 V per cell, corresponding to approximately 9.0 V for a 3S pack. ↩
Richard Fitzpatrick, University of Texas at Austin, "Emf and Internal Resistance." The lecture models a real battery as an emf source with internal resistance and shows that its terminal voltage decreases as load current increases, explaining load-induced voltage sag. ↩
Same Sky, "What is the Most Effective Way to Commutate a BLDC Motor?" The article explains that BLDC motors are powered from a DC source through an electronic controller that commutates the motor phases. It also describes how PWM allows the controller to regulate the effective voltage applied to the motor even when the DC-bus voltage differs from the motor's rated voltage. ↩
Eneronix, "BMS Protection Explained." The article explains that high discharge current can produce voltage drops in a battery system and that a BMS can disconnect or limit the load when discharge current exceeds its configured over-current protection threshold. ↩
All About Circuits, "An Explanation of Undervoltage Lockout." The article explains that UVLO disables downstream circuitry when the supply falls below an acceptable threshold, keeping the circuit in a controlled state rather than allowing unpredictable operation at insufficient voltage. ↩
Wikipedia, "Lithium-ion battery." The article discusses the upper charging voltage and lower protection or shutoff limits used with lithium-ion cells and battery packs, illustrating why both the fully charged voltage and lower cutoff boundary are important integration parameters. ↩
Jianxiong Chen, "Estimation of Motor Startup Speed Profile Using Low-Resolution Timing Signals and Motor Speed-Torque Curve," Purdue University. The paper models motor startup as a transient process in which motor-developed torque, load torque, rotational speed, and inertia determine acceleration, showing why startup torque requirements must be considered separately from steady-state operation. ↩