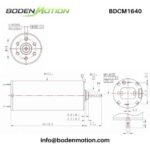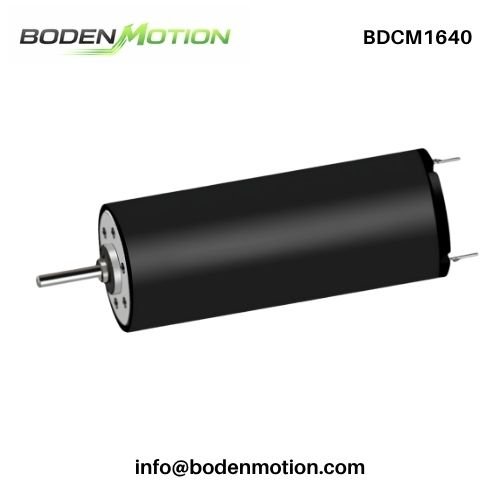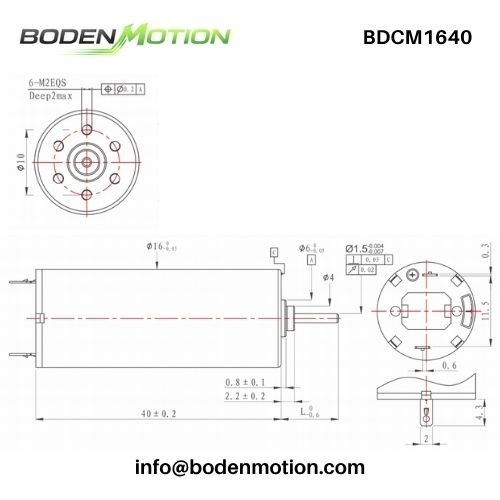
The BDCM1640 micro brushed DC motor uses a slim Ø16 mm diameter with a 40 mm body length, giving OEM designers a longer motor platform without increasing radial installation space. With a 30 g body and typical noise of 38 dB or lower, it is suited to compact mechanisms where quiet operation, simple DC control, and a narrow motor envelope are important.
Four winding versions support 6V, 9V, 12V, and 24V power systems. Rated speed ranges from 6,372 to 11,635 rpm, while rated torque reaches 3.19 mN·m on the 9V version. The platform can also be combined with an optional planetary gearbox or photoelectric / magnetoelectric encoder when the final mechanism requires gearing or feedback.
The four versions use different winding designs. Supply voltage, operating current, speed, torque constant, and load requirements should therefore be considered together when choosing the final motor.
| Motor Model | Unit | BDCM1640-01 | BDCM1640-02 | BDCM1640-03 | BDCM1640-04 |
|---|---|---|---|---|---|
| At Nominal | |||||
| Nominal Voltage | V/DC | 6 | 9 | 12 | 24 |
| Nominal Speed | rpm | 9,847 | 11,635 | 6,372 | 6,489 |
| Nominal Current | A | 0.47 | 0.54 | 0.14 | 0.07 |
| Nominal Torque | mN·m | 2.20 | 3.19 | 1.92 | 1.87 |
| Free Load | |||||
| No-load Speed | rpm | 11,002 | 13,000 | 7,120 | 7,250 |
| No-load Current | mA | 40 | 50 | 15 | 13 |
| At Max. Efficiency | |||||
| Maximum Efficiency | % | 81.2 | 80.3 | 78.6 | 72.5 |
| Speed | rpm | 9,902 | 11,700 | 6,408 | 6,525 |
| Current | A | 0.446 | 0.516 | 0.131 | 0.071 |
| Torque | mN·m | 2.1 | 3.0 | 1.8 | 1.8 |
| At Max. Output Power | |||||
| Maximum Output Power | W | 6.0 | 10.3 | 3.4 | 3.4 |
| Speed | rpm | 5,501 | 6,500 | 3,560 | 3,625 |
| Current | A | 2.1 | 2.4 | 0.6 | 0.3 |
| Torque | mN·m | 10.5 | 15.2 | 9.2 | 8.9 |
| At Stall | |||||
| Stall Current | A | 4.10 | 4.70 | 1.17 | 0.59 |
| Stall Torque | mN·m | 20.9 | 30.4 | 18.4 | 17.8 |
| Motor Constants | |||||
| Terminal Resistance | Ω | 1.46 | 1.91 | 10.26 | 40.68 |
| Terminal Inductance | mH | 0.073 | 0.071 | 0.452 | 1.75 |
| Torque Constant | mN·m/A | 5.11 | 6.47 | 15.68 | 30.23 |
| Speed Constant | rpm/V | 1,833.7 | 1,444.4 | 593.3 | 302.1 |
| Speed/Torque Constant | rpm/mN·m | 525.5 | 427.6 | 388.0 | 406.1 |
| Mechanical Time Constant | ms | 7.22 | 6.15 | 5.28 | 5.32 |
| Rotor Inertia | g·cm² | 1.31 | 1.32 | 1.30 | 1.23 |
| Number of Pole Pairs | — | 1 | 1 | 1 | 1 |
| Number of Phases | — | 5 | 5 | 5 | 5 |
| Weight | g | 30 | 30 | 30 | 30 |
| Typical Noise Level | dB | ≤38 | ≤38 | ≤38 | ≤38 |
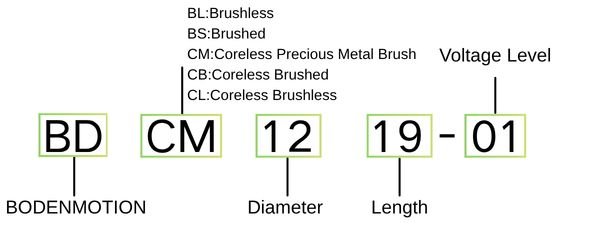
Not sure how to interpret model differences? See the model code breakdown below ↓
For a low-noise motor, final acoustic performance depends heavily on how the motor is mounted and loaded. The coupling, bracket, gearbox, and surrounding housing can introduce vibration that is not represented by the motor-level noise specification.
Radial and Axial Loading
Maximum dynamic axial load is 0.5 N, while maximum radial load is 5 N measured 5 mm from the flange. Gears, pulleys, or offset couplings should be arranged so excessive side loading is not transferred to the motor shaft.
Mechanical Clearance
Axial play is specified at 0.05–0.15 mm, and radial play is limited to 0.012 mm. Accurate shaft alignment helps reduce additional friction and vibration.
Press-Fit Control
Maximum static press-fit force is 15 N. Installation force should be applied through the appropriate structural surfaces rather than through the output shaft.
Noise-Sensitive Mounting
A rigid mounting structure can improve positional stability but may also transmit vibration into the equipment enclosure. Prototype testing should therefore evaluate the complete assembled mechanism rather than the unloaded motor alone.
Operating Environment
The motor is specified for ambient temperatures from −20°C to +80°C, relative humidity below 90% at 25°C, and rotor temperatures up to 125°C.
Current Margin
The lower-voltage windings require higher operating and peak current. Wiring, switches, connectors, and the DC source should be sized according to the selected winding and actual load cycle.
The BDCM1640 can be adapted around the required power platform, transmission design, feedback method, and installation constraints of the OEM system.
| Customization Item | Available Options / Description |
|---|---|
| Winding Version | 6V, 9V, 12V, or 24V configuration |
| Planetary Gearbox | Optional for reduced output speed and increased transmitted torque |
| Encoder Option | Optional photoelectric or magnetoelectric encoder |
| Operating Point | Winding selection based on target speed, torque, current, and duty cycle |
| Shaft Configuration | Shaft dimensions and geometry can be reviewed for the driven mechanism |
| Wiring / Lead Length | Connection arrangement can be adapted to the equipment layout |
| Connector Type | Connector requirements can be reviewed for the OEM harness |
| Mounting Interface | Mechanical adaptation can be evaluated for the final assembly |
| Prototype Combination | Motor, gearbox, and optional encoder can be evaluated together before production |
The gearbox and encoder are optional additions to the base motor configuration.
The BDCM1640 is well suited to mechanisms that can accommodate a 40 mm motor length and benefit from low acoustic output, simple brushed control, and moderate torque.
The BDCM1640 is particularly useful when a narrow motor diameter must be retained but the application can accept a longer motor body. Selecting the correct winding still requires balancing speed, current, torque, noise, and the required duty cycle.
Germany | Analytical Equipment Manufacturer
Application: internal sample positioning mechanism
Feedback: The narrow Ø16 mm motor frame simplified installation while the low acoustic output helped keep additional equipment noise under control.
Japan | Precision Instrument OEM
Application: optical adjustment drive
Feedback: The longer motor platform provided sufficient performance margin without requiring an increase in the diameter of the existing mechanical housing.
United States | Automation Equipment Developer
Application: compact geared actuator
Feedback: The optional gearbox allowed the output speed to be reduced for the mechanism while retaining the same 16 mm motor platform.
[BDCM1640 Micro Precious Metal Brushed Coreless DC Motor Specification PDF]
A1: Each voltage version uses a different winding design. The 9V version is rated at 3.19 mN·m and 11,635 rpm, while the 12V and 24V versions use different resistance and torque-constant characteristics. Selection should therefore be based on the complete operating point rather than voltage alone.
A2: The motor-level specification does not include vibration or acoustic amplification from brackets, housings, couplings, gears, and driven components. Mounting stiffness and alignment should therefore be checked in the assembled system.
A3: Not automatically. The 10.3 W value belongs to the 9V version at a 6,500 rpm operating point with 2.4 A current. Continuous suitability should be confirmed through load-cycle, temperature, and brush-life testing.
A4: There is no strict MOQ for standard evaluation orders. Sample quantities, pilot batches, and production orders can be arranged according to the project stage and customization requirements.
A5: Yes. The BDCM1630 uses a shorter Ø16 × 30 mm body and belongs to the same 3–7W product class. It is more suitable when axial installation space is tighter, while the BDCM1640 offers a longer Ø16 × 40 mm mechanical format.
For compact OEM mechanisms requiring a narrow precious-metal brushed motor with low acoustic output, BODENMOTION supports selection around the complete electrical, mechanical, and operating requirements.
📧 Email: info@bodenmotion.com
🌐 Website: https://bodenmotion.com