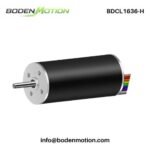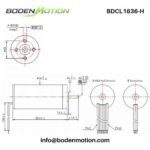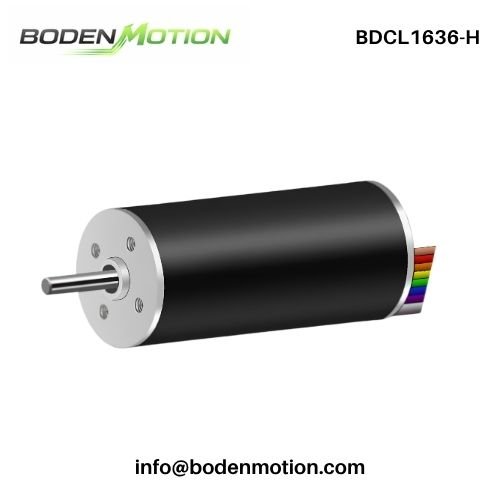
The BDCL1636-H high speed coreless brushless DC motor is designed for compact OEM systems where rotational speed and power density are more important than low-speed direct torque. Its Ø16 × 36 mm coreless architecture supports rated speeds above 49,000 rpm across all winding versions while maintaining a compact motor envelope.
This platform is particularly suited to miniature blowers, micro pumps, compact compressors, high-speed spindles, and analytical equipment. Hall-sensored or sensorless configurations are available, with bearing, gearbox, and encoder options for different mechanical and control requirements.
The four versions use different winding configurations. Voltage, current capacity, target speed, torque demand, and driver limits should therefore be evaluated together rather than treating the windings as interchangeable supply settings.
| Motor Model | Unit | BDCL1636-H-01 | BDCL1636-H-02 | BDCL1636-H-03 | BDCL1636-H-04 |
|---|---|---|---|---|---|
| At Nominal | |||||
| Nominal Voltage | V/DC | 12 | 18 | 24 | 36 |
| Nominal Speed | rpm | 56,550 | 50,895 | 54,375 | 49,590 |
| Nominal Current | A | 2.67 | 1.66 | 1.32 | 0.95 |
| Nominal Torque | mN·m | 4.19 | 4.20 | 4.13 | 4.76 |
| Free Load | |||||
| No-load Speed | rpm | 65,000 | 58,500 | 62,500 | 58,000 |
| No-load Current | mA | 260 | 200 | 170 | 130 |
| At Max. Efficiency | |||||
| Maximum Efficiency | % | 77.9 | 75.3 | 74.4 | 72.3 |
| Speed | rpm | 58,175 | 51,773 | 55,313 | 50,460 |
| Current | A | 2.207 | 1.488 | 1.185 | 0.867 |
| Torque | mN·m | 3.40 | 3.72 | 3.65 | 4.27 |
| At Max. Output Power | |||||
| Maximum Output Power | W | 54.9 | 49.5 | 52.0 | 49.9 |
| Speed | rpm | 32,500 | 29,250 | 31,250 | 29,000 |
| Current | A | 9.5 | 5.8 | 4.6 | 3.0 |
| Torque | mN·m | 16.10 | 16.17 | 15.88 | 16.43 |
| At Stall | |||||
| Stall Current | A | 18.80 | 11.40 | 9.00 | 5.80 |
| Stall Torque | mN·m | 32.20 | 32.33 | 31.77 | 32.85 |
| Motor Constants | |||||
| Terminal Resistance | Ω | 0.64 | 1.58 | 2.67 | 6.21 |
| Terminal Inductance | mH | 0.020 | 0.051 | 0.086 | 0.210 |
| Torque Constant | mN·m/A | 1.74 | 2.89 | 3.60 | 5.79 |
| Speed Constant | rpm/V | 5,416.7 | 3,250.0 | 2,604.2 | 1,611.1 |
| Speed/Torque Constant | rpm/mN·m | 2,017 | 1,809 | 1,967 | 1,765 |
| Mechanical Time Constant | ms | 7.66 | 6.87 | 7.47 | 6.70 |
| Rotor Inertia | g·cm² | 0.36 | 0.36 | 0.36 | 0.36 |
| Number of Pole Pairs | — | 1 | 1 | 1 | 1 |
| Number of Phases | — | 3 | 3 | 3 | 3 |
| Weight | g | 23 | 23 | 23 | 23 |
| Typical Noise Level | dB | ≤55 | ≤55 | ≤55 | ≤55 |
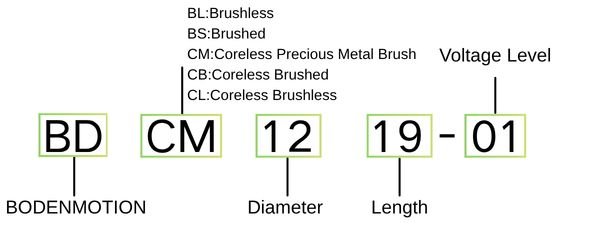
Not sure how to interpret model differences? See the model code breakdown below ↓
At rotational speeds approaching 60,000 rpm, the quality of the complete rotating assembly becomes particularly important. Motor alignment, bearing selection, driven-component balance, and controller behavior should be evaluated together during prototype integration.
Shaft Load Limits
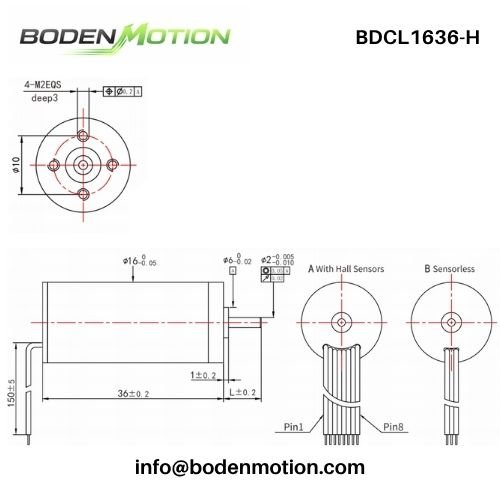
The bearing system supports a maximum dynamic axial load of 0.8 N and a maximum radial load of 8 N, measured 5 mm from the flange.
High-Speed Alignment
Couplings, impellers, and other rotating components should be mounted concentrically. At elevated speed, small alignment or balance errors can increase vibration and bearing loading.
Bearing Selection
Both ball-bearing and sleeve-bearing configurations are available. The appropriate option should be selected according to rotational speed, radial load, noise requirements, and expected operating cycle.
Mechanical Clearance
Axial play is specified at 0.05–0.15 mm, while radial play is limited to 0.015 mm.
Press-Fit Protection
Maximum static press-fit force is 10 N. Assembly force should be controlled to avoid transferring excessive load through the shaft or bearing structure.
Thermal Environment
Ambient temperature is specified from −20°C to +80°C, relative humidity below 90% RH at 25°C, and maximum rotor temperature at 85°C.
Driver Current Margin
Rated current ranges from 0.95 to 2.67 A, while stall current reaches 5.8–18.8 A depending on the winding. The BLDC driver should provide appropriate transient-current capacity and protection.
The BDCL1636-H can be configured around the power supply, controller architecture, bearing requirements, transmission design, and feedback needs of the OEM system.
| Customization Item | Available Options / Description |
|---|---|
| Winding Version | 12V, 18V, 24V, or 36V configuration |
| Control Configuration | Hall-sensored or sensorless arrangement |
| Bearing Type | Ball bearing or sleeve bearing |
| Planetary Gearbox | Optional for reduced output speed and increased transmitted torque |
| Encoder Option | Optional magnetoelectric encoder |
| Cable Length | Can be adapted according to controller and equipment layout |
| Connector Type | Connector format can be reviewed for the OEM harness |
| Wire Sequence | Cable, connector, and phase sequence can be customized |
| Shaft Interface | Shaft requirements can be reviewed for the driven component |
| Prototype Configuration | Motor, bearing, feedback, gearbox, and encoder combination can be evaluated before production |
Hall-sensored versions provide Hall Sensor A, B, and C together with a 3.5–25 VDC VHall supply, while sensorless versions use the three motor-phase connections.
The BDCL1636-H is most relevant to compact systems where very high rotational speed and relatively high power density are more important than low-speed direct torque.
Final selection should consider load inertia, aerodynamic or mechanical resistance, driver current, bearing configuration, cooling, and continuous operating time.
A motor operating above 50,000 rpm requires different integration priorities from a conventional miniature BLDC motor. Rotating balance, current capacity, bearing choice, thermal conditions, and the real operating point can determine system reliability as much as the headline speed.
Germany | Miniature Blower Manufacturer
Application: compact high-speed airflow module
Feedback: The Ø16 × 36 mm motor platform allowed the impeller assembly to remain compact while providing the rotational speed required by the airflow target.
Japan | Analytical Instrument OEM
Application: miniature rotary sampling mechanism
Feedback: The 24V winding provided a useful balance between high operating speed and current demand within the existing power architecture.
United States | Industrial Equipment Developer
Application: high-speed sensor-assisted rotary module
Feedback: The Hall-sensor configuration simplified startup and controller integration while retaining the same compact motor platform.
[BDCL1636-H High Speed Coreless Brushless DC Motor Specification PDF]
A1: The 56,550 rpm value applies to the 12V winding at its nominal operating point. Mechanical or aerodynamic load, voltage drop, controller limitations, insufficient current capacity, and bearing or coupling losses can reduce the final operating speed.
A2: It should not automatically be treated as a continuous rating. The 54.9W value occurs on the 12V version at 32,500 rpm and 9.5 A, which is substantially different from the nominal operating point. Continuous suitability should be confirmed through temperature and duty-cycle testing.
A3: Hall feedback is useful when the controller requires defined rotor-position information or more predictable startup behavior. Sensorless operation reduces wiring complexity and may suit applications where the controller can start and commutate the motor reliably without position sensors.
A4: Yes. Samples can normally be shipped by FedEx or DHL, while bulk orders can be arranged by air or sea according to quantity and destination.
| BDCL1636 | BDCL1636-H | |
|---|---|---|
| Motor Size | Ø16 × 36 mm | Ø16 × 36 mm |
| Main Positioning | Higher torque | High speed |
| Rated Speed | 14,276–15,355 rpm | 49,590–56,550 rpm |
| Power Class | 7–18W | 25–55W |
| Best For | Actuators, grippers | Blowers, pumps, spindles |
A5: Yes. The BDCL1636 uses the same Ø16 × 36 mm mechanical size but operates in a much lower rated-speed range of approximately 14,276–15,355 rpm with a 7–18W power class. It is more suitable when higher torque at moderate speed is more important than the BDCL1636-H’s 50,000+ rpm operating range.
For OEM projects requiring very high rotational speed from a compact Ø16 mm motor platform, BODENMOTION supports configuration selection around the complete motor, driver, rotating load, and thermal system.
📧 Email: info@bodenmotion.com
🌐 Website: https://bodenmotion.com