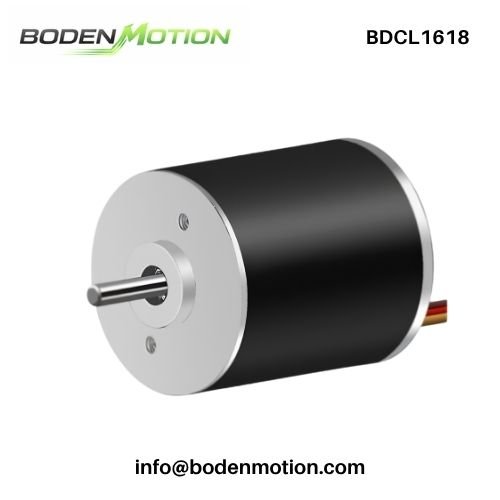
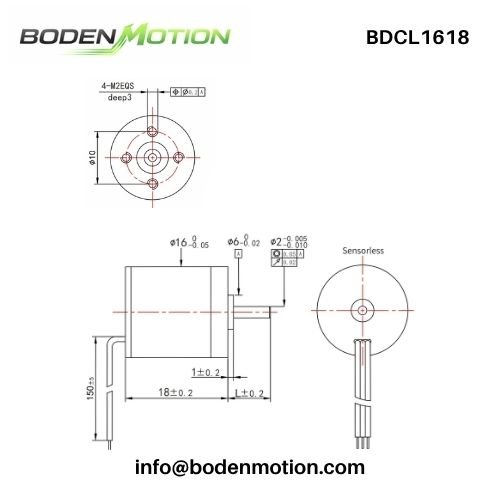
The BDCL1618 coreless mini motor is built around an unusually short Ø16 × 18 mm body, making axial space the defining consideration for this platform. At only 18 g, the motor provides a compact brushless drive option for embedded mechanisms where a larger or longer BLDC motor would complicate the mechanical layout.
Four winding versions support 9V, 12V, 18V, and 24V, with rated speeds from 8,624 to 11,935 rpm and rated torque from 0.90 to 1.13 mN·m. The platform also supports sensorless or Hall-sensored wiring, while a magnetoelectric encoder is available as an optional component when additional motion feedback is required.
Each suffix represents a different winding configuration. The selected voltage should be matched with the available driver, allowable current, target speed, and real mechanical load rather than treated as an interchangeable supply setting.
| Motor Model | Unit | BDCL1618-01 | BDCL1618-02 | BDCL1618-03 | BDCL1618-04 |
|---|---|---|---|---|---|
| At Nominal | |||||
| Nominal Voltage | V/DC | 9 | 12 | 18 | 24 |
| Nominal Speed | rpm | 11,550 | 8,624 | 11,935 | 11,165 |
| Nominal Current | A | 0.28 | 0.12 | 0.14 | 0.10 |
| Nominal Torque | mN·m | 1.11 | 0.90 | 1.13 | 1.10 |
| Free Load | |||||
| No-load Speed | rpm | 15,000 | 11,200 | 15,500 | 14,500 |
| No-load Current | mA | 70 | 30 | 30 | 25 |
| At Max. Efficiency | |||||
| Maximum Efficiency | % | 53.7 | 54.6 | 57.0 | 53.7 |
| Speed | rpm | 11,850 | 8,904 | 12,478 | 11,455 |
| Current | A | 0.261 | 0.114 | 0.122 | 0.093 |
| Torque | mN·m | 1.00 | 0.80 | 0.96 | 1.00 |
| At Max. Output Power | |||||
| Maximum Output Power | W | 1.9 | 1.1 | 2.0 | 1.8 |
| Speed | rpm | 7,500 | 5,600 | 7,750 | 7,250 |
| Current | A | 0.5 | 0.2 | 0.3 | 0.2 |
| Torque | mN·m | 2.40 | 1.95 | 2.45 | 2.38 |
| At Stall | |||||
| Stall Current | A | 0.98 | 0.44 | 0.50 | 0.35 |
| Stall Torque | mN·m | 4.80 | 3.91 | 4.90 | 4.77 |
| Motor Constants | |||||
| Terminal Resistance | Ω | 9.18 | 27.27 | 36.00 | 68.57 |
| Terminal Inductance | mH | 0.019 | 0.045 | 0.076 | 0.145 |
| Torque Constant | mN·m/A | 5.32 | 9.53 | 10.42 | 14.68 |
| Speed Constant | rpm/V | 1,666.7 | 933.3 | 861.1 | 604.2 |
| Speed/Torque Constant | rpm/mN·m | 3,098 | 2,865 | 3,164 | 3,040 |
| Mechanical Time Constant | ms | 3.67 | 3.40 | 3.75 | 3.60 |
| Rotor Inertia | g·cm² | 0.11 | 0.11 | 0.11 | 0.11 |
| Number of Pole Pairs | — | 1 | 1 | 1 | 1 |
| Number of Phases | — | 3 | 3 | 3 | 3 |
| Weight | g | 18 | 18 | 18 | 18 |
| Typical Noise Level | dB | ≤50 | ≤50 | ≤50 | ≤50 |
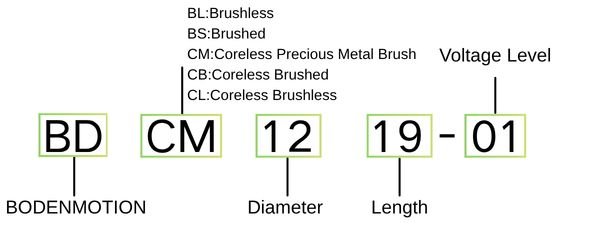
Not sure how to interpret model differences? See the model code breakdown below ↓
The short motor body reduces installation length, but the complete rotating assembly still needs accurate alignment and controlled shaft loading to preserve bearing performance and operating stability.
Shaft Load Limits
Maximum dynamic axial load is 0.8 N, while maximum radial load is 8 N when measured 5 mm from the flange. Driven components should be positioned to avoid unnecessary overhung loading.
Bearing Selection
Both ball-bearing and sleeve-bearing options are available. Bearing choice can be evaluated around radial loading, operating speed, acoustic target, expected duty cycle, and project cost.
Mechanical Clearance
Axial play is specified at 0.05–0.15 mm, and radial play is limited to 0.015 mm. Coupling alignment and shaft concentricity should be controlled during assembly.
Press-Fit Protection
The maximum static press-fit force is 10 N. Assembly force should not be transferred improperly through the output shaft or bearing structure.
Thermal Environment
The motor is specified for ambient temperatures from −20°C to +80°C, with relative humidity below 90% RH at 25°C and a maximum rotor temperature of 85°C.
Controller Integration
The motor is three-phase brushless and therefore requires a compatible electronic driver. Startup behavior, phase current, current limiting, and feedback configuration should be checked with the actual mechanical load.
The BDCL1618 can be configured around the available controller, required feedback method, installation space, and final transmission design.
| Customization Item | Available Options / Description |
|---|---|
| Winding Version | Standard 9V, 12V, 18V, or 24V configuration |
| Feedback Configuration | Sensorless or Hall-sensored motor configuration |
| Encoder Option | Optional magnetoelectric encoder for additional motion feedback |
| Bearing Type | Ball bearing or sleeve bearing |
| Planetary Gearbox | Optional gearbox for reduced speed and increased output torque |
| Cable Length | Lead length can be adapted to the equipment layout |
| Connector Type | Connector can be reviewed according to the controller interface |
| Pinout | Cable, connector, and pin sequence can be customized |
| Shaft Interface | Shaft requirements can be reviewed for the driven mechanism |
| Prototype Configuration | Motor, sensor, encoder, or gearbox combination can be validated before production |
For Hall-sensored configurations, the Hall supply range is 3.5–25 VDC. The standard sensorless interface uses three motor phases, while the Hall version adds Hall A, B, C, supply, and ground connections.
The BDCL1618 is most useful when short motor length and low moving mass are more important than maximum torque or power.
Final configuration should be selected according to available space, driver architecture, load inertia, target speed, operating time, and feedback requirements.
In an 18 mm-long motor platform, packaging decisions can become just as important as electrical performance. Driver location, cable routing, bearing choice, feedback hardware, and gearbox length can significantly change the final assembly dimensions.
Germany | Optical Equipment Manufacturer
Application: compact adjustment module
Feedback: The 18 mm motor length reduced the depth of the motion assembly while maintaining the speed required for repeated adjustment cycles.
Japan | Portable Instrument OEM
Application: miniature internal drive
Feedback: The low motor weight and short body simplified the mechanical layout in a handheld device where internal space was tightly constrained.
United States | Automation Module Developer
Application: encoder-assisted positioning mechanism
Feedback: The optional feedback configuration allowed additional motion monitoring while retaining the same compact brushless motor platform for the actuator design.
[BDCL1618 Coreless Mini Brushless DC Motor Specification PDF]
A1: No. The magnetoelectric encoder is an optional component. The required encoder configuration should be specified when defining the final motor assembly.
A2: Hall sensors provide rotor-position information primarily for brushless commutation and startup control, while an encoder can provide additional motion feedback for applications requiring more detailed speed or position information. The two should therefore be selected according to different control requirements.
A3: Each voltage version uses a different winding design. The 18V version is rated at 11,935 rpm and 1.13 mN·m, while the other windings provide different combinations of voltage, current, speed, and torque. The correct version depends on the complete system operating point.
A4: BODENMOTION supports PayPal, credit card, and T/T. Final payment arrangements can be confirmed according to order quantity, customization requirements, and project stage.
A5: Yes. The BDCL1525 uses a Ø15 × 25 mm body and belongs to the 25–65W power class, with rated speeds reaching 60,450 rpm. It is more suitable where considerably higher speed and output power are required and the additional axial length can be accommodated.
For OEM projects where motor length, controller architecture, and feedback options all compete for limited installation space, BODENMOTION can support selection from the complete mechanism rather than treating the motor as an isolated component.
📧 Email: info@bodenmotion.com
🌐 Website: https://bodenmotion.com